Nachdem hier eh nur noch gespammt wird nutzen wir die neue Seite um die bisherigen Ergebnisse zusammenzufassen:
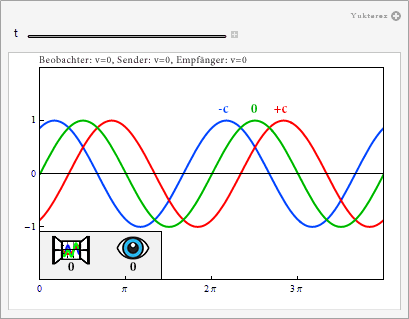
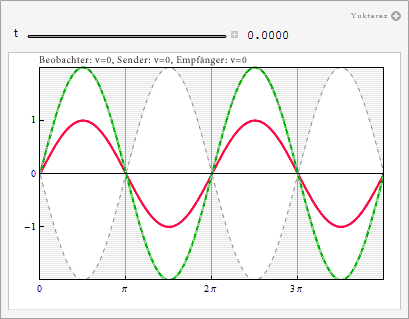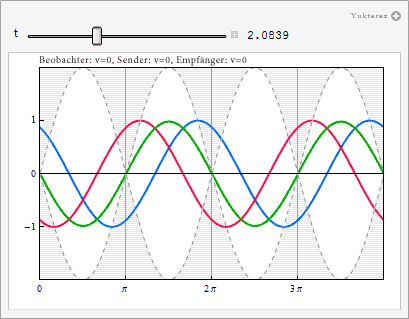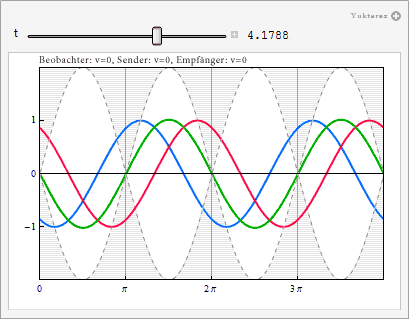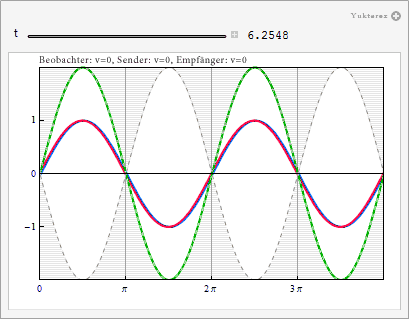
ruhendes Inertialsystem mit Fokus auf die ruhende Resonatorkammer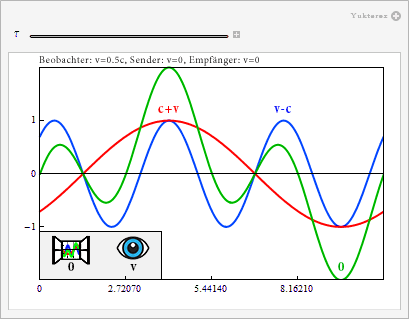

bewegtes Inertialsystem mit Fokus auf die ruhende Resonatorkammer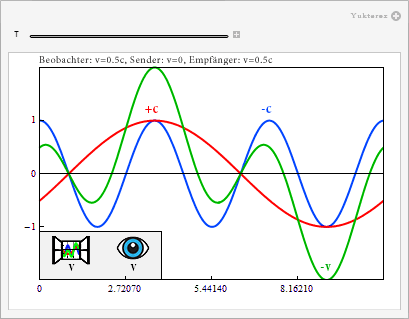
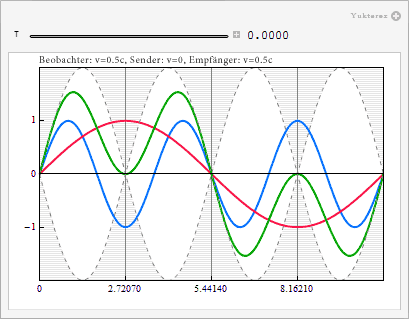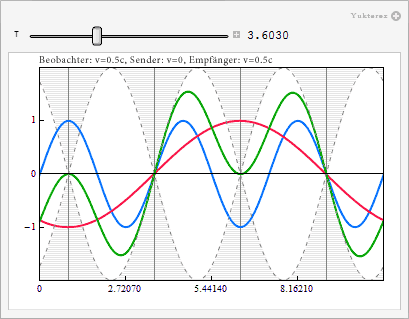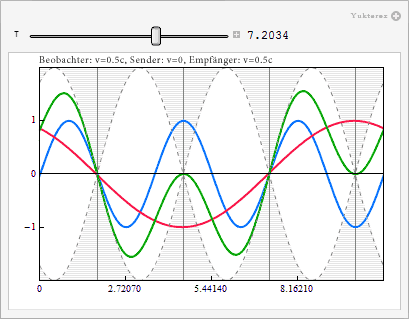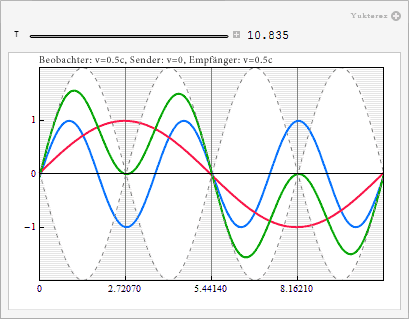
bewegtes Inertialsystem mit Fokus auf ein mitbewegtes FensterCode:
(* Variablen *) v = c/2;
c = 1;
d1 = Sqrt[(c+v)/(c-v)];
d2 = 1/d1;
γ = 1/Sqrt[1-v^2/c^2];
λ = 2 π;
(* ruhendes Inertialsystem mit Fokus auf den ruhenden Sender *)
p1 = Manipulate[Plot[{
(* B *) Sin[x + c t],
(* R *) Sin[x - c t],
(* G *) Sin[x + c t] + Sin[x - c t],
2 Sin[x],
2 Sin[x + π]
}, {x, 0, 4 π},
Frame -> True,
PlotRange -> {{0, 4 π}, {-2, 2}},
GridLines -> {{π, 2 π, 3 π}, {}},
PlotStyle -> {Blue, Red, Green, Dashed, Dashed},
FrameTicks -> {{{-1, 0, 1}, None},
{{0, π, 2 π, 3 π}, None}}],
{t, 0, λ/c}]
(* bewegtes Inertialsystem mit Fokus auf den ruhenden Sender *)
p2 = Manipulate[Plot[{
(* B *) Sin[d1 x + c τ/γ],
(* R *) Sin[d2 x - c τ/γ],
(* G *) Sin[d1 x + c τ/γ] + Sin[d2 x - c τ/γ],
2 Sin[x γ],
2 Sin[π + x γ]
}, {x, 0, 4 π/γ},
Frame -> True,
PlotRange -> {{0, 4 π/γ}, {-2, 2}},
GridLines -> {{π/γ, 2 π/γ, 3 π/γ}, {}},
PlotStyle -> {Blue, Red, Green, Dashed, Dashed},
FrameTicks -> {{{-1, 0, 1}, None},
{{0, N[π/γ, 6], N[2 π/γ, 6], N[3 π/γ, 6]}, None}}],
{τ, 0, λ/c γ}]
(* bewegtes Inertialsystem mit Fokus auf den bewegten Empfänger *)
p3 = Manipulate[Plot[{
(* B *) Sin[d1 x + c т d1],
(* R *) Sin[d2 x - c т d2],
(* G *) Sin[d1 x + c т d1] + Sin[d2 x - c т d2],
2 Sin[x γ + c т d2],
2 Sin[π + x γ + c т d2]
}, {x, 0, 4 π/γ},
Frame -> True,
PlotRange -> {{0, 4 π/γ}, {-2, 2}},
GridLines -> {Table[n π/γ - v т, {n, 1, 12}], {}},
PlotStyle -> {Blue, Red, Green, Dashed, Dashed},
FrameTicks -> {{{-1, 0, 1}, None},
{{0, N[π/γ, 6], N[2 π/γ, 6], N[3 π/γ, 6]}, None}}],
{т, 0, 2 λ/c/γ}]
Zusammenfassend,

 Anmelden
 Registrieren
 FAQ
 Suche


 ,


 ,

